Self-Driving Car with Lane Detection and Obstacle Detection Using Raspberry Pi & OpenCV
Project Price Starts From ₹15,000
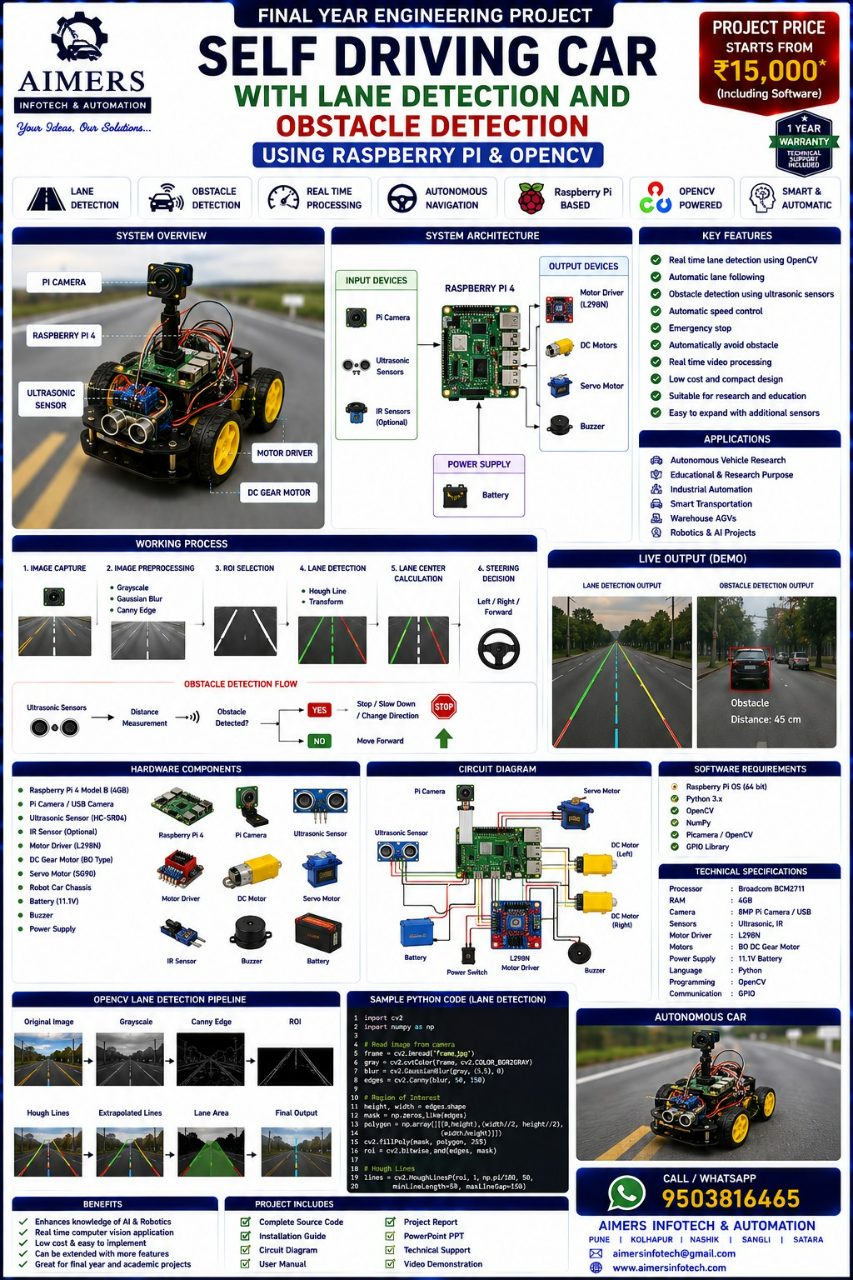
The Self-Driving Car with Lane Detection and Obstacle Detection Using Raspberry Pi & OpenCV is a small autonomous vehicle designed to follow a road lane and detect obstacles automatically.
The Raspberry Pi camera continuously captures the road image. OpenCV processes the image to identify lane markings using techniques such as grayscale conversion, Gaussian blur, edge detection, Region of Interest (ROI), and Hough Line Transform. Based on the detected lane position, the Raspberry Pi controls the motors and automatically adjusts the vehicle direction.
At the same time, ultrasonic sensors measure the distance from obstacles. If an obstacle is detected within the configured safety distance, the vehicle automatically slows down, stops, or changes direction. The project demonstrates the basic concepts of autonomous driving using computer vision and embedded control.
OpenCV-Based Features
📷 Real-Time Camera Processing
🛣️ Lane Line Detection
🎯 Region of Interest (ROI)
🔍 Canny Edge Detection
📐 Hough Line Transform
↔️ Lane Position/Center Calculation
🚗 Automatic Steering Decision
🚧 Obstacle Detection
🛑 Automatic Emergency Stop
Objectives
✅ Automatic Lane Following
✅ Real-Time Road Image Processing
✅ Lane Departure Detection
✅ Obstacle Detection
✅ Automatic Steering Control
✅ Automatic Speed Control
✅ Emergency Stop Function
✅ Raspberry Pi-Based Processing
✅ Low-Cost Autonomous Vehicle Prototype
✅ Real-Time Camera Monitoring
Working Process
Camera Capture → Image Preprocessing → Grayscale → Blur → Canny Edge Detection → ROI Selection → Lane Detection → Lane Center Calculation → Steering Decision → Motor Control
Parallel:
Ultrasonic Sensor → Distance Measurement → Obstacle Detected → Stop/Slow/Turn
Web Dashboard Features — Optional
📷 Live Camera Feed
🛣️ Detected Lane Position
🚗 Vehicle Direction
🚧 Obstacle Distance
⚡ Motor Status
🛑 Emergency Stop
📊 Sensor Data
📅 Driving/Detection Logs
Applications
🚗 Autonomous Vehicle Research
🏫 Educational Robotics
🏭 Industrial Autonomous Vehicles
📦 Warehouse AGVs
🛣️ Smart Transportation Research
🤖 Robotics & AI Projects
🎓 Computer Vision Projects
📦 Includes:
✅ Complete Python Source Code • OpenCV Lane Detection • Obstacle Detection • Raspberry Pi Setup • Motor Control • Circuit Diagram • Documentation • Project Report • Installation Guide • User Manual • Technical Support